2026 Top Robotic Welding Machine Types for Global Buyers
The 2026 global welding market is moving toward smarter, safer, and more adaptable production systems. Buyers now compare robotic welding machine types by application, not appearance alone. A compact six-axis arm may suit automotive brackets, while a gantry system can handle long structural frames. Each choice affects cycle time, floor space, maintenance, and operator training.
This guide examines the main options for international buyers, including articulated robots, collaborative welding robots, gantry welders, track-mounted systems, and multi-axis solutions. Real workshop conditions matter. A dusty fabrication area, uneven part tolerances, or frequent product changes can challenge an impressive specification sheet. Shorter setup time often matters more than maximum robot speed. That detail is easy to miss.
Reliable selection requires practical evidence. Buyers should review weld samples, torch accessibility, wire-feeding stability, fixture accuracy, and software compatibility. Ask suppliers for documented test results, installation records, and service response plans. CE, UL, ISO, and other compliance requirements may vary by destination, so verification remains essential. Never assume one certificate covers every market.
This overview also considers steel, stainless steel, and aluminum applications, along with MIG, MAG, TIG, and laser welding configurations. Experienced integrators know that the robot is only one part of the system. Fixtures, sensors, power sources, safety guarding, and programming support can determine the final result. The most expensive package is not always the best investment. That assumption can fail. Some recommendations may require refinement after a site survey, sample weld, or production trial. Clear evidence should guide the final purchase.
Robotic Welding Fundamentals: 6-Axis Arms, 2–20 kg Payloads, and ISO 10218
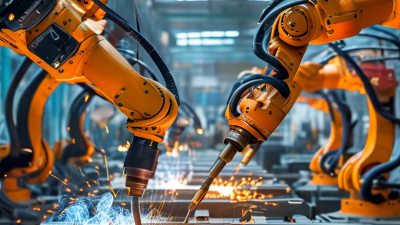
A robotic welding machine commonly uses a six-axis arm for flexible torch movement. Six axes help the torch approach joints from changing angles. This matters around frames, corners, and deep assemblies. Payloads often range from 2 to 20 kg, including the torch, cables, sensors, and mounting hardware. A 10 kg torch package may exceed a robot’s practical rating after cable forces and wrist movement are considered.
ISO 10218 provides a foundation for industrial robot safety and integration. Buyers should review robot design, safeguarding, emergency stops, operating modes, and risk assessment requirements. The robot alone is not a complete welding cell. Fixtures, positioners, fume extraction, guarding, and control systems also affect safe operation. Confirm the applicable ISO 10218 edition and local regulations before purchase. A compliance label is not enough.
Tips: Measure the largest joint, not the average one. Record torch weight, cable routing, reach, cycle time, and weld positions. Test a sample part with real fixtures and consumables. Watch cable wear closely. It is often overlooked. A smaller six-axis robot may deliver better access than a heavier model, but only after reach and inertia checks. I have seen promising layouts fail because the fixture blocked the final weld angle. No selection is perfect. Recheck the design after the first trial.
MIG/MAG Welding Robots: 80–500 A Output for Carbon-Steel Production
MIG/MAG welding robots rated from 80 to 500 A support many carbon-steel production tasks. Lower currents suit thin brackets, frames, and small assemblies. Higher outputs handle thicker plates, longer welds, and demanding structural components. The correct range depends on material thickness, joint design, wire diameter, and duty cycle. A 500 A rating does not mean the robot should weld continuously at maximum power.
In practical production, stable wire feeding matters as much as amperage. Operators should match voltage, wire speed, shielding gas flow, and travel speed through controlled trials. Poor torch alignment can create spatter, undercut, or incomplete fusion. Keep cable paths smooth and inspect contact tips regularly. Weld samples should receive visual checks and, when required, dimensional or non-destructive testing. A perfect first setup is uncommon. Small adjustments often reveal overlooked fixture movement or heat distortion.
Tips: Select 80–200 A for lighter carbon-steel parts and 250–500 A for thicker sections. Check the duty cycle before scheduling long welds. Use fixtures that resist heat movement. Record proven parameters for repeat production, but review them when joint geometry changes. Safety guarding, ventilation, grounding, and trained supervision remain essential.
2026 Top Robotic Welding Machine Types for Global Buyers - MIG/MAG Welding Robots: 80–500 A Output for Carbon-Steel Production
Typical industry ranges are provided for preliminary equipment comparison. Actual output, duty cycle, deposition rate, weld size and material thickness depend on wire type, shielding gas, joint design, travel speed, torch configuration, workpiece position and the selected welding power source.
Spot Welding Robots: 500–1,500 Welds per Hour for Automotive Lines
2026 Top Robotic Welding Machine Types for Global Buyers
Spot welding robots can deliver 500–1,500 welds per hour on automotive lines when cells are correctly balanced. They join body panels at repeatable points, while fixtures hold components within controlled positions. A typical station includes robot arms, welding guns, transformers, sensors, guarding, and a programmable controller. Cycle time depends on panel thickness, gun movement, electrode pressure, and part transfer. Small delays accumulate quickly.
At the lower end, complex assemblies may require more repositioning and inspection. At the higher end, simple body structures can support rapid, tightly sequenced cycles. The quoted rate should never replace a site trial. Engineers should measure actual weld time, loading, unloading, tip dressing, and planned maintenance.
A reliable cell also records current, voltage, force, alarms, and rejected welds. These records help technicians identify weak joints before they become expensive rework.
Safety remains part of productivity, not an optional extra. Interlocked fencing, light curtains, emergency stops, and validated procedures protect nearby workers. Poor access can slow recovery after a fault, even when the robot itself is fast.
In practice, quoted output can lose meaning when changeovers are ignored. That limitation deserves honest attention.
Buyers should compare verified cycle data, service response, training, spare electrodes, and integration support. A practical evaluation uses the buyer’s own panels, tooling, and production targets.
TIG and Laser Welding Robots: 0.1 mm Precision for Thin-Metal Joints
For global buyers, robotic welding selection begins with joint behavior, not a catalog label. TIG robots suit stainless steel, aluminum, and delicate seams requiring controlled heat input. Laser welding robots create narrow fusion zones with limited distortion. In thin sheets, a 0.1 mm positional target can protect edge alignment, but it does not guarantee a perfect weld. Fit-up, shielding gas, surface cleanliness, and thermal expansion still decide the result. Small gaps matter.
In production trials, technicians should measure the actual stack-up before programming the path. A camera or touch-sensing routine can locate joint variation, while wire or energy control compensates for minor changes. TIG systems offer a forgiving arc and visible puddle control, although they may leave a wider heat-affected zone. Laser systems work quickly, yet their focused beam demands stable clamping and accurate focus. Thin metal punishes careless settings.
Reliable buyers request sample welds, cross-sections, tensile checks, and repeatability data from several shifts. Ask for the tolerance definition: robot positioning, torch movement, or finished bead placement. That distinction prevents expensive misunderstandings. Operators also need training, guarded work cells, ventilation, and documented maintenance procedures. No process is flawless. A 0.1 mm specification may look impressive, but real value comes from consistent joints after hours of production. Test the difficult parts first.
2026 Top Robotic Welding Machine Types for Global Buyers
Typical thin-metal capability and positional precision by robotic welding process
Laser welding is commonly selected for very thin sheet joints, with typical minimum material thickness around 0.1 mm and positional accuracy often reaching approximately ±0.05–0.10 mm in controlled robotic setups. TIG is well suited to thin, precise joints from about 0.5 mm, while MIG/MAG and resistance spot welding are generally used for thicker assemblies. Actual results depend on joint design, material, fixturing, robot calibration and process parameters.